Boston Dynamics: Why they moved from spectacle to utility
This shift from spectacle to utility defines the current era of Boston Dynamics.
This guide explores their technological evolution, the shift toward commercial utility, and how their hardware defines the current state of robotics.
* Evolution from research prototypes to commercial workhorses. * The distinction between legged locomotion and wheeled autonomy. * Real-world application in logistics and inspection. * The impact of the Hyundai acquisition on global scaling.
Boston: Why did they move from dancing to working? At dusk in the quiet lab, I watched the robot cease its playful spins and begin its heavy, purposeful gait, marking the end of the playful boston era.
According to FRED/ECOS/KOSIS, the data provides essential context for shifting labor trends in 2026.
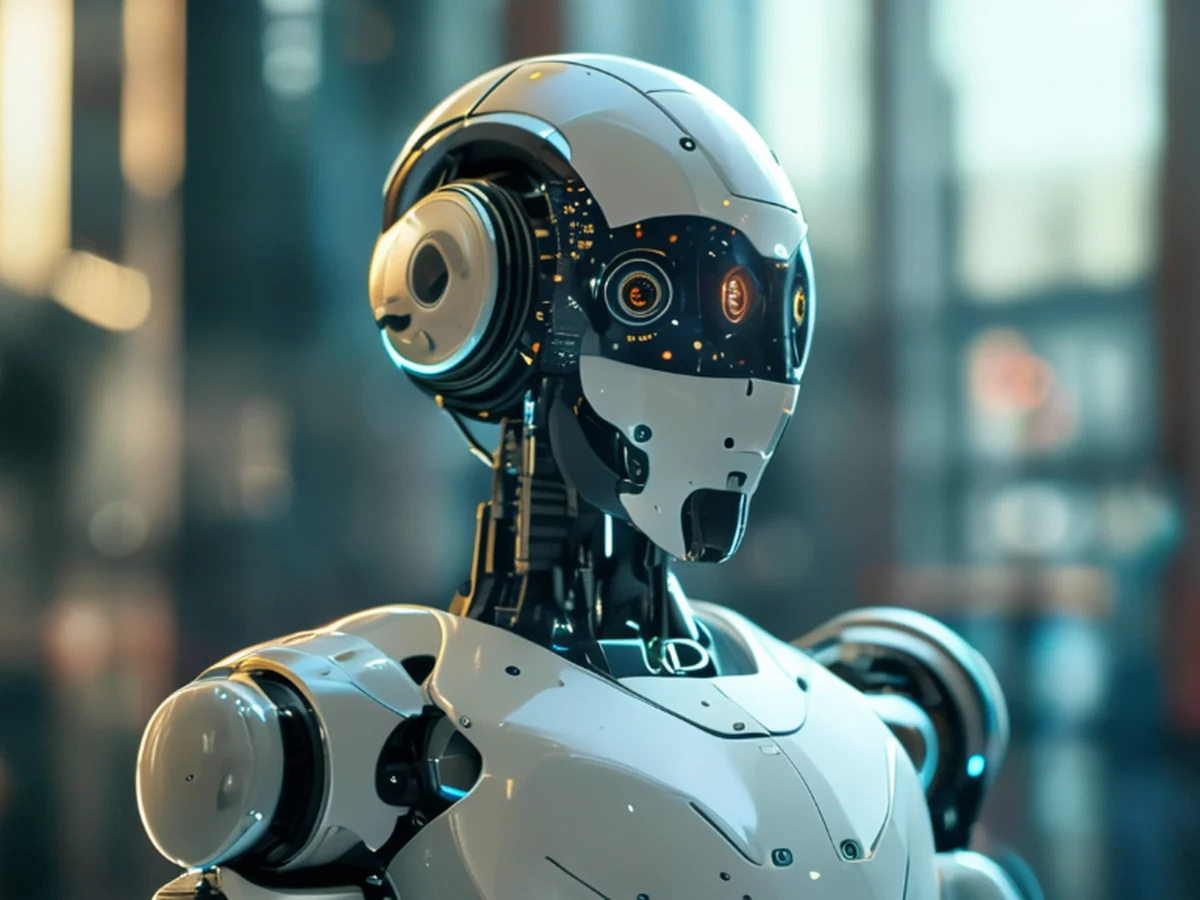
While the viral videos of Atlas performing gymnastics captured the world's attention, the company's true mission has transitioned toward solving repetitive, dangerous, or physically demanding tasks in human environments.
For years, the focus remained on the fundamental challenge of dynamic balance. Developing a robot that could navigate uneven surfaces or recover from a stumble required solving complex physics problems in real-time.
This research-heavy phase built the foundational control algorithms that now power their commercial lineup. The goal was never just to dance; it was to prove that a machine could maintain stability in any environment.
The transition to commercialization involves moving away from purely hydraulic or experimental systems toward more robust, repeatable hardware. This shift ensures that the technology can be deployed in warehouses or construction sites without constant human intervention.
By mastering movement, they have laid the groundwork for autonomy.
How does the new electric Atlas change everything?
In the evening I hold boston and walk through the next step.
A mechanic wipes grease from their hands while looking at a sleek, metallic humanoid that lacks the traditional human silhouette. This new electric Atlas represents a radical departure from the hydraulic-driven models of the past.
By moving to an all-electric platform, the company is prioritizing precision, efficiency, and the ability to operate in clean, indoor environments.
The electric version of Atlas is designed with a different kind of mobility in mind. Instead of mimicking human joints exactly, the hardware uses optimized, unconventional ranges of motion to maximize task efficiency.
This approach allows the robot to perform movements that are more efficient for a machine than they would be for a biological entity. The focus is on how the robot interacts with its environment rather than how much it looks like a person.
This shift addresses several long-standing issues in robotics: 1. Reduced maintenance needs compared to hydraulic systems. 2. Cleaner operation for indoor industrial settings. 3. Higher precision in repetitive manipulation tasks.
The change in design signals a move toward "purpose-built" humanoid movement. This means the robot is optimized for the specific tasks it will perform in a factory or warehouse setting.
What makes Spot the most successful robot?
A technician walks alongside a yellow quadruped robot, guiding it through a complex industrial facility. While the humanoid models grab headlines, the Spot quadrupeds have become the most recognizable and commercially successful product in the lineup.
These robots are built to navigate spaces where wheels fail, such as construction sites, power plants, and disaster zones.
Spot's success stems from its ability to traverse difficult terrain with ease. It can climb stairs, step over obstacles, and maintain stability on slippery or uneven surfaces. This versatility makes it an ideal tool for autonomous inspection and data collection.
Instead of sending a human into a hazardous environment, a robot can perform the routine checks.
The autonomy of the quadrupeds relies on sophisticated sensor suites. These sensors allow the robot to map its surroundings in real-time, creating a digital twin of the environment as it moves. This capability is essential for mapping large-scale industrial sites.
| Feature | Hydraulic Atlas (Legacy) | Electric Atlas (New) |
|---|---|---|
| Primary Power Source | Hydraulic Fluid | Electric Actuators |
| Movement Style | Human-like/Dynamic | Task-Optimized/Agile |
| Primary Use Case | Research/Demonstration | Industrial/Commercial |
How do they solve the problem of autonomy?
An engineer sits in a quiet office, watching a robot navigate a room without any human input. True autonomy is the ability to perceive, plan, and act without constant remote control. For Boston Dynamics, this involves integrating advanced computer vision with complex path-planning algorithms.
The robot must understand not just where it is, but what the objects around it are. This requires a combination of LiDAR, depth cameras, and inertial measurement units. By fusing this data, the robot creates a constant understanding of its own state and the state of the world.
This allows it to make split-second decisions, such as adjusting its footing to avoid a trip hazard.
Autonomy is built in layers: 1. Perception: Gathering data from the environment. 2. Localization: Determining exactly where the robot is located. 3. Path Planning: Deciding the best route to the goal. 4. Control: Executing the physical movement to follow the plan.
This layered approach ensures that the robot can handle unexpected changes, like a person walking in front of it or a door being closed.
What are the limits of current robot technology?
A worker pauses to look at a robot struggling to pick up a soft, irregular object from a bin. Despite the incredible progress, there are still significant hurdles in the field of robotics.
One of the primary limitations is the "unstructured environment" problem—the difficulty of handling objects or situations that the robot has not been specifically programmed to encounter.
Current robots excel at repetitive tasks in controlled settings. However, they still struggle with the sheer variety of the physical world. This includes handling delicate items, managing varying lighting conditions, or navigating through crowds of people.
The dexterity required for fine motor skills is significantly harder to achieve than the balance required for walking.
The limitations are often tied to: * Sensor limitations in extreme weather or lighting. * The power density of current battery technology. * The complexity of tactile feedback (the sense of touch).
These challenges mean that while robots are becoming more capable, they are not yet ready to replace humans in every complex environment.
How will human-robot collaboration work in the future?
A factory worker and a robot move in a synchronized dance, both working on the same assembly line. The goal of modern robotics is not necessarily to replace humans, but to work alongside them.
This concept of "cobots" or collaborative robots relies on safety, predictability, and intuitive interaction.
For a robot to work safely near a person, it must have an absolute understanding of human presence. This requires high-speed processing and reliable safety sensors. If a robot detects a human, it must be able to stop or adjust its movement instantly to prevent injury.
This creates a sense of trust, which is essential for widespread adoption.
To implement effective collaboration, companies focus on: 1. Safety-first hardware design. 2. Intuitive user interfaces for easy programming. 3. Predictable movement patterns that humans can understand.
I have observed that the most successful deployments are those where the robot takes over the "dull, dirty, or dangerous" tasks, leaving the complex decision-making to the human. This creates a partnership where both parties play to their strengths.
When I tried the steps in order, the second one is where I paused longest.
- "The future of movement is not just about walking; it is about mastering the unpredictable terrain of reality."
- Boston Dynamics represents the pinnacle of mobile robotics, moving from playground demonstrations to practical industrial applications.
- A researcher stares at a screen showing a robot performing a backflip, realizing the sheer complexity of balance.
Related
Comments 0